Robot Vision
We commonly use 2D vision in our robot cells to quickly adapt to changes in part presentation. Cameras are mounted in one of two locations, either stationary above the object in question, or on the end of the robot arm.
Typically these cameras are utilized to adjust for location of a specific feature of a part that is critical in the next step. For example, we can use robot vision to accurately find the center of a cylindrical part, which can remove an additional step of placing the part in a jig to locate properly.
Additionally, we can use the same camera to perform necessary quality checks, including bar-code scanning, image or color presence, and dimensional measurements.
How It Works
Fanuc 2D iRVision is calibrated via a grid system that locates the camera in relation to the robot world zero point. With this information, we can accurately locate and dimension parts to pick, sort, and quality check as the application requires.
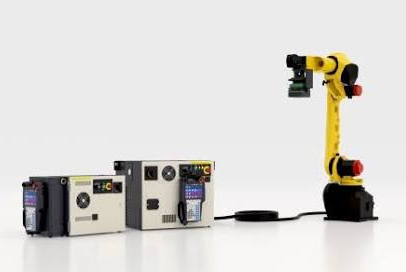
FANUC Robots are iRVision Ready
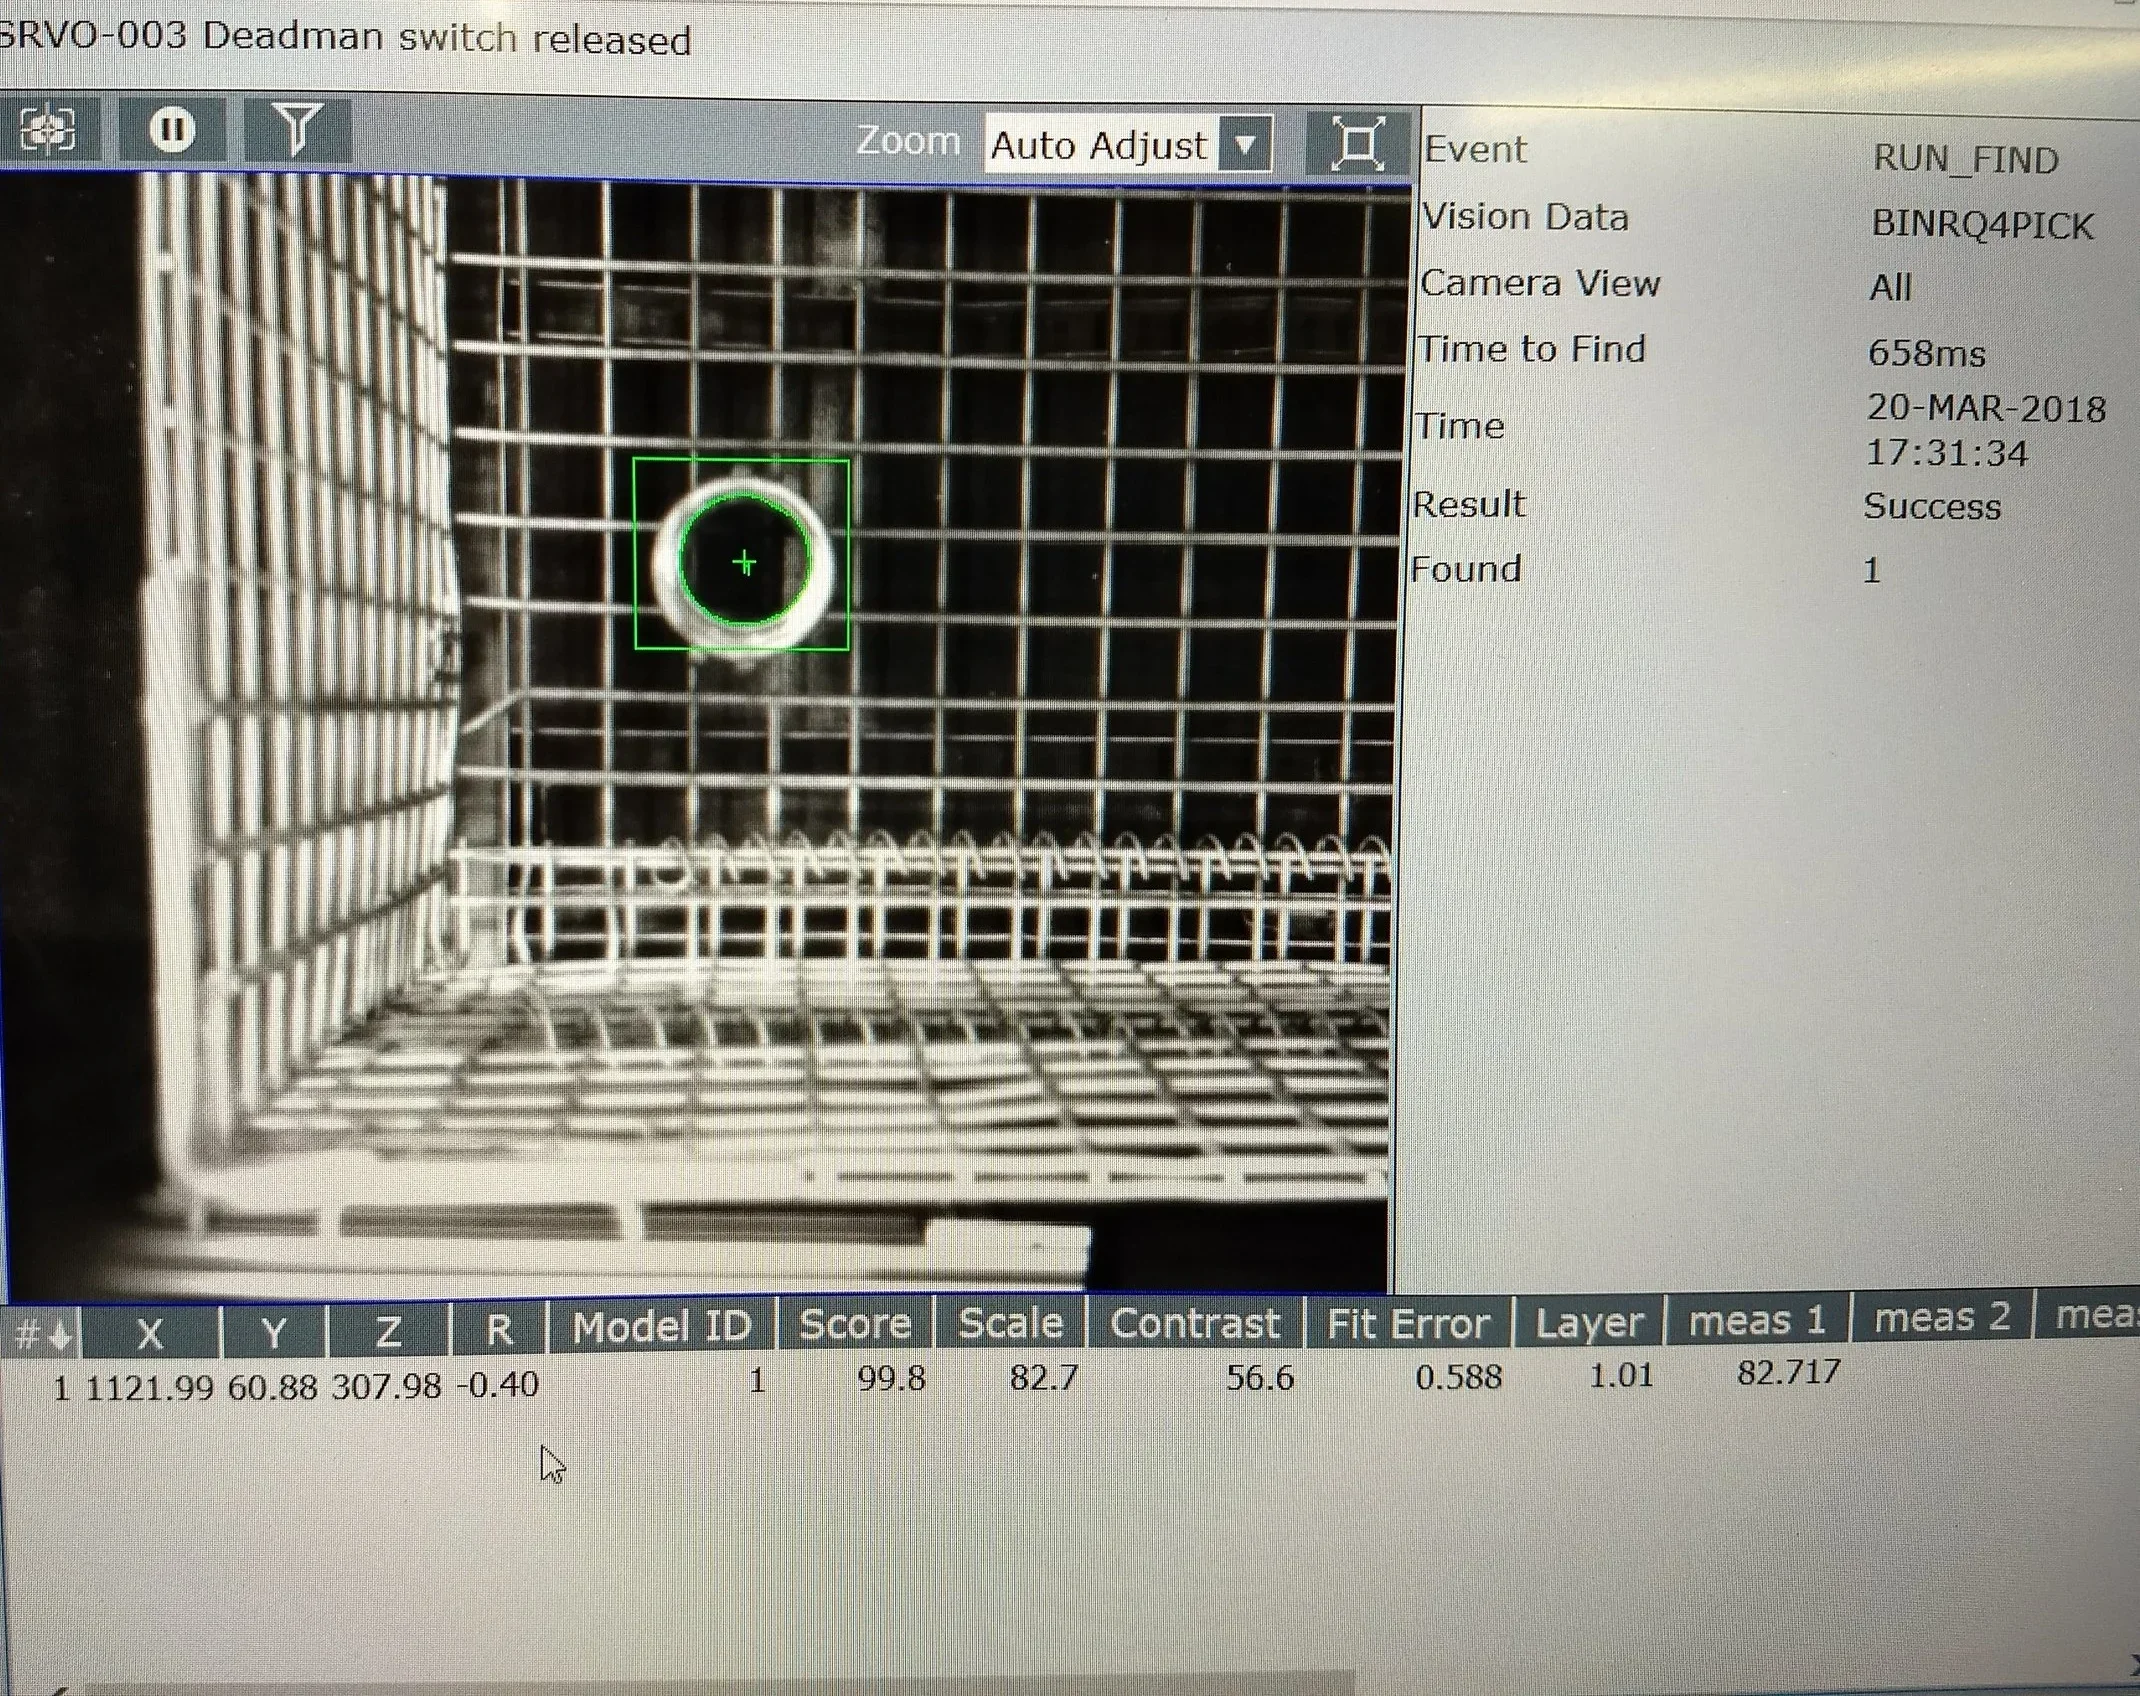
Vision Teaching Example